
Speaker: Professor Hiroyuki Sugiyama
University of Iowa, USA
December 10, 2026 | 11:00 EDT / 17:00 CET / 01:00 JST (next day)
Modeling and Simulation
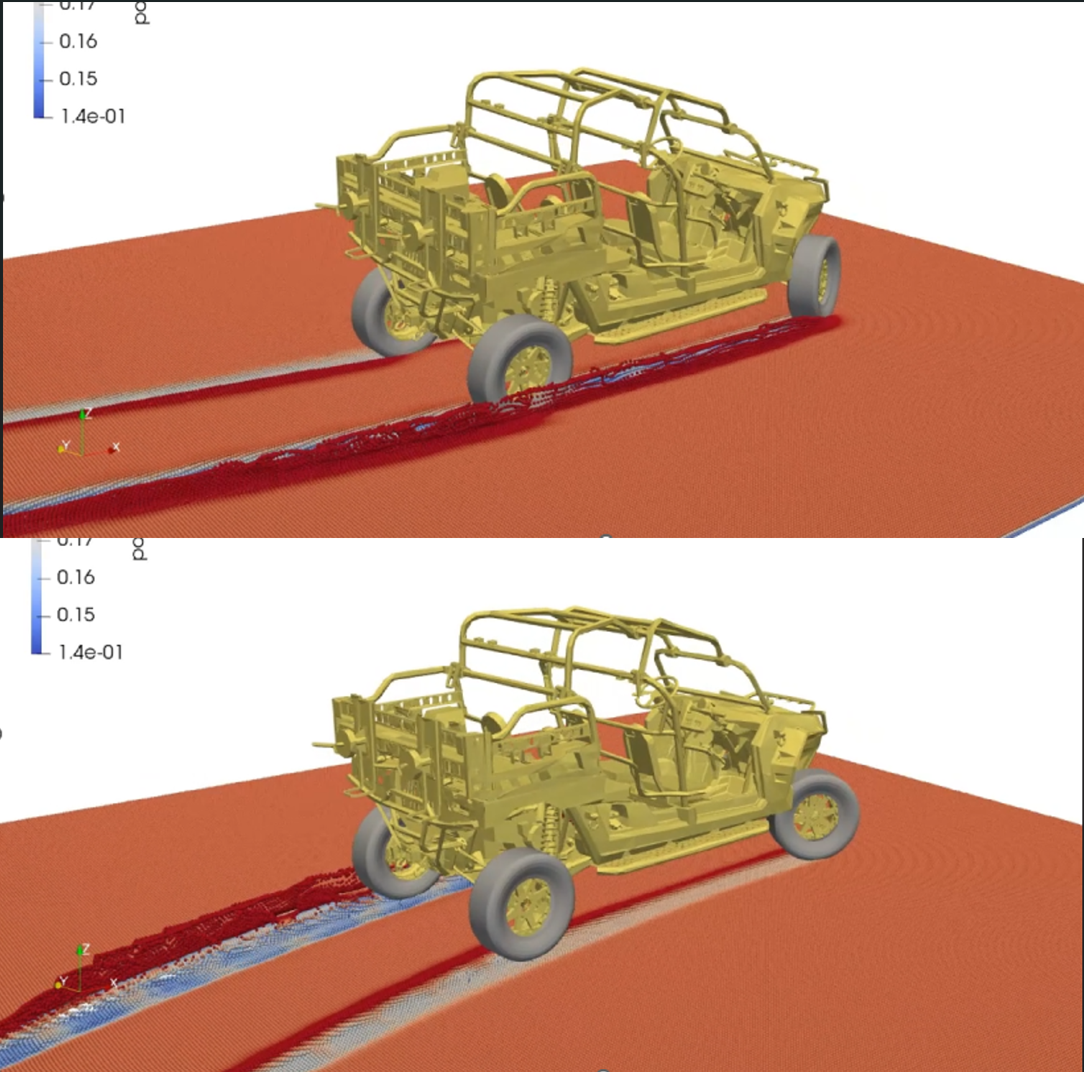
Virtual testing of autonomous mobility systems is essential for evaluating the robustness of local trajectory planners across various topographies and stochastic soil conditions. However, high-fidelity physics-based tire-soil interaction models lead to prohibitively high computational costs, while computationally cheaper classical terramechanics models have limited ability to capture transient tire-soil interaction behavior due to the quasi-static and semi-empirical modeling assumptions. To address these challenges, this talk presents a new grid-based data-driven transient tire-soil contact model. The compact tire-soil contact kinematic description in the classical terramechanics model is generalized to account for three-dimensional, nonuniform transient contact stress distributions using a grid contact patch, while the effect of transient granular soil material flow is incorporated through neural networks at the local grid contact level to preserve the physical structure of the tire-soil contact calculation. This enables computationally efficient off-road mobility predictions while maintaining accuracy comparable to the high-fidelity model and preserving the interpretability of the predicted solutions. The accuracy and computational efficiency of the proposed approach are discussed, along with validation against field test data.
P A P E R S
https://doi.org/10.1115/1.4069963
https://doi.org/10.1007/s11044-026-10196-z
S P E A K E R B I O
Professor Sugiyama
University of Iowa logo
Hiroyuki Sugiyama is a Professor in the Department of Mechanical Engineering at the University of Iowa. He received his Ph.D. from the University of Illinois at Chicago in 2005. His research interests include computational multibody dynamics, high-fidelity off-road mobility simulation, data-driven modeling, tire dynamics, and rail dynamics. He is an Associate Editor of the ASME Journal of Computational and Nonlinear Dynamics and an editorial board member of Multibody System Dynamics, IMechE Journal of Multi-Body Dynamics, and International Journal of Vehicle Performance.
Certificate of Attendance provided on request: To request a Certificate of Attendance after attending the event, please email gs@istvs.org. Your attendance will be verified, and the certificate will be issued.